Interfaces and Pinout
The board uses two MCUs with the same pin definition. Each chip manages two CAN/FDCAN interfaces and two RS485 interfaces. STM32(1) manages CAN-1/2 and RS485-1/2; STM32(2) manages CAN-3/4 and RS485-3/4.
The external USB connector is connected to
PA11 (DM)/PA12 (DP)on both MCUs.The external SPI connector is connected to
PD0 (CS)/PD1 (SCK)/PD3 (MISO)/PD4 (MOSI)on both MCUs. SCK/MISO/MOSI are shared; CS0 connects to the first MCU, STM32(1), and CS1 connects to the second MCU, STM32(2).
Download the schematic: SCH_Schematic_v8_gb1.pdf
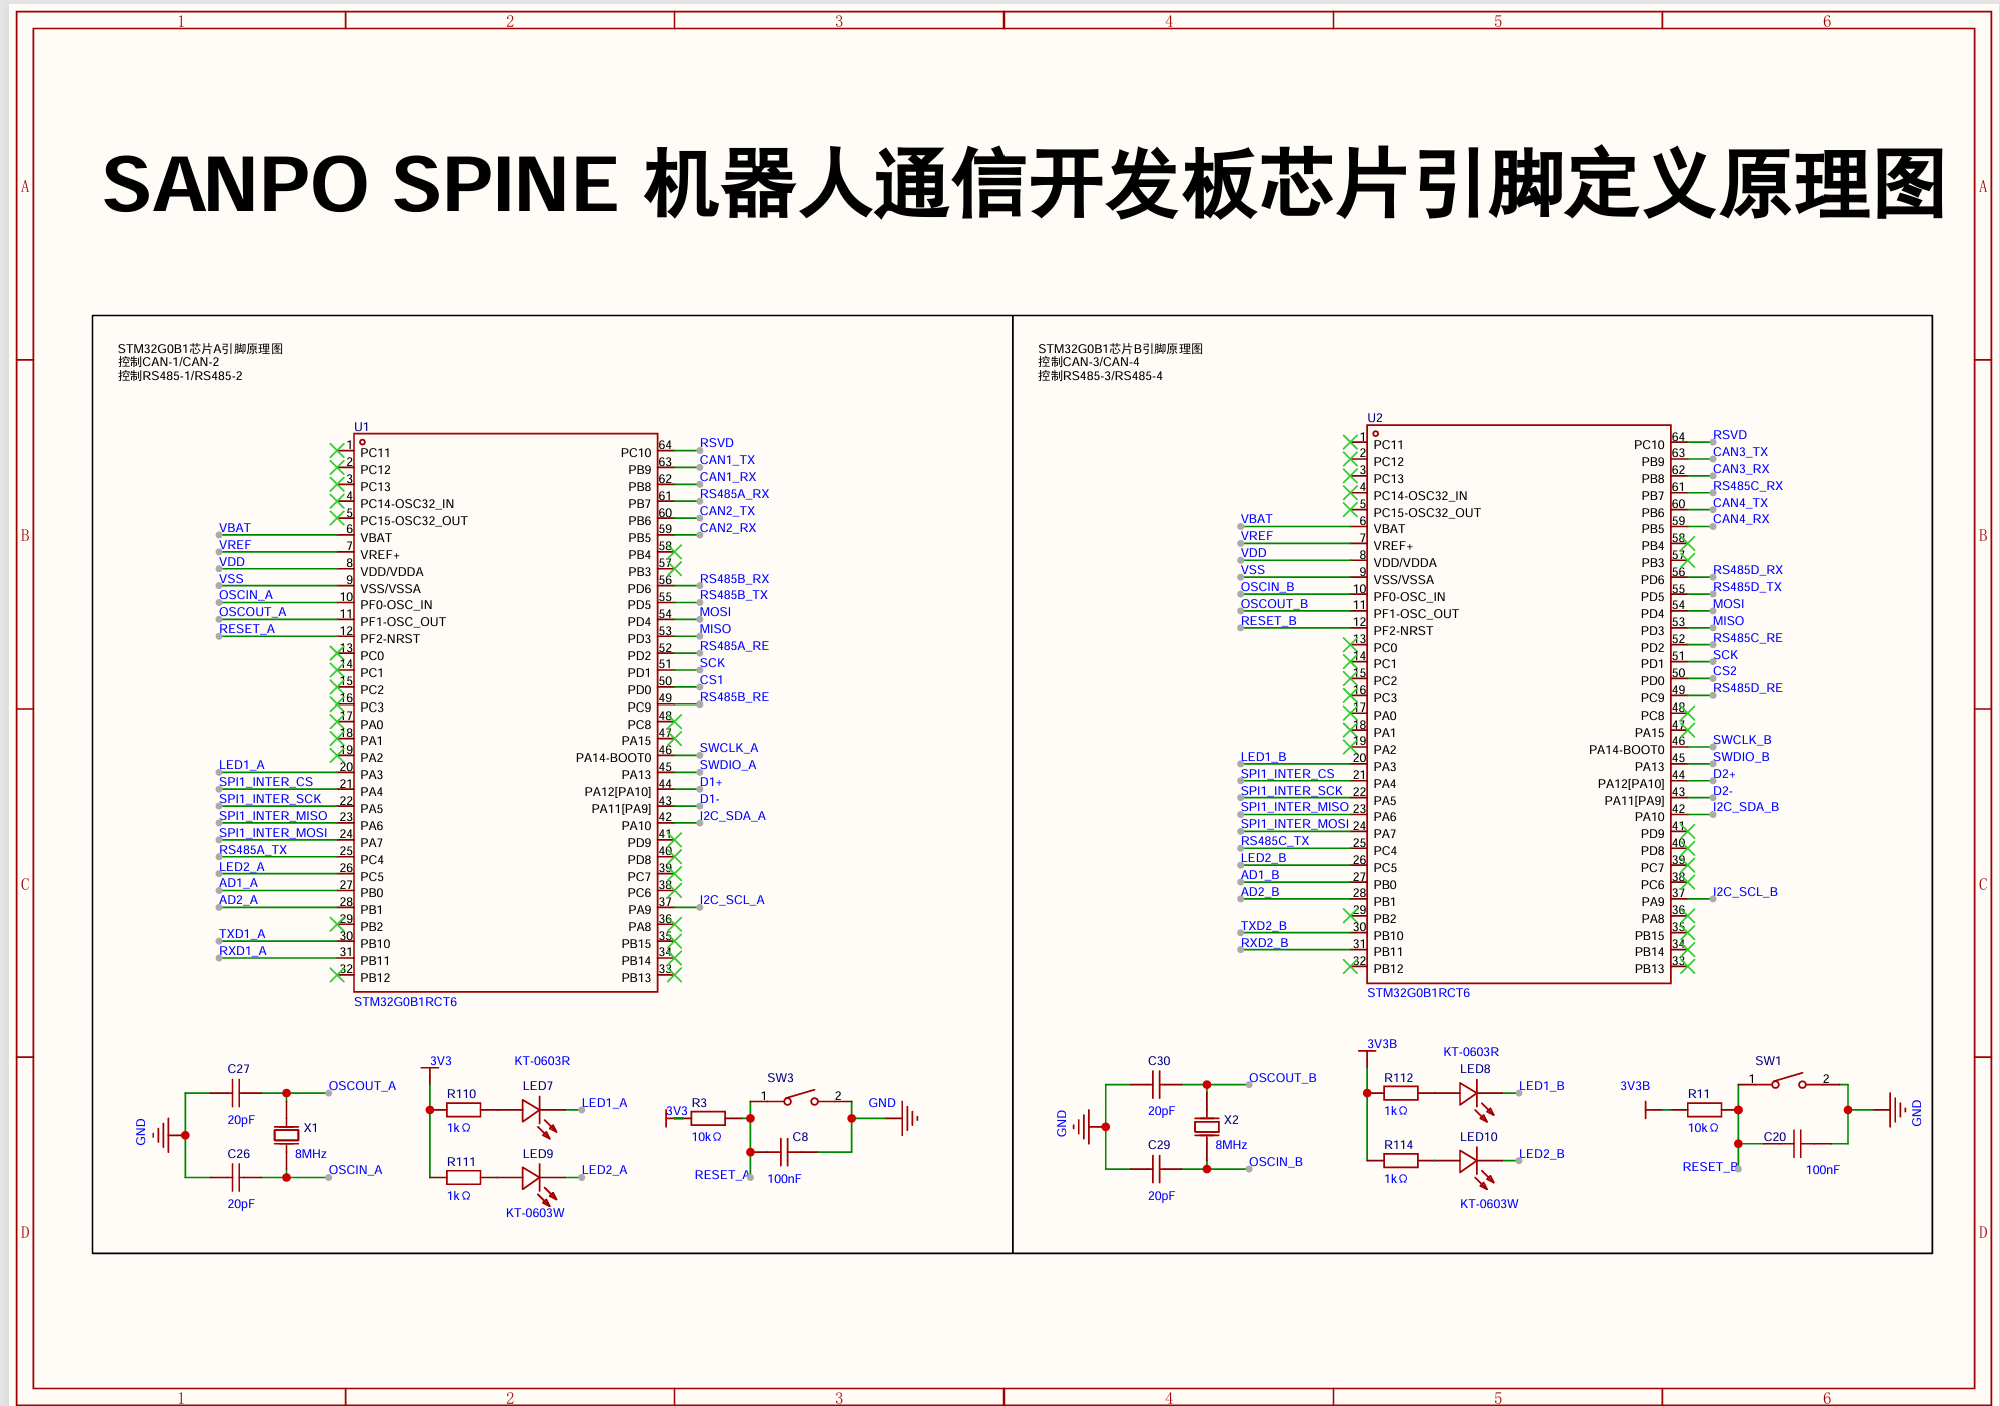
Pins on Each MCU
Function |
MCU pins |
Description |
|---|---|---|
FDCAN1 RX / TX |
|
First CAN/CAN FD interface |
FDCAN2 RX / TX |
|
Second CAN/CAN FD interface |
RS485-A TX / RX / RE |
|
USART1, first RS485 interface |
RS485-B TX / RX / RE |
|
USART2, second RS485 interface |
External SPI CS / SCK / MISO / MOSI |
|
SPI2 slave, connected to the external host |
Internal SPI CS / SCK / MISO / MOSI |
|
SPI1, board-level connection between the two MCUs |
Debug UART TX / RX |
|
USART3 |
I²C SCL / SDA |
|
I2C1 |
ADC input 1 / 2 |
|
ADC1 channels 8 / 9 |
LED1 / LED2 |
|
Active low |
USB DM / DP |
|
USB composite device |
SWDIO / SWCLK |
|
ST-LINK programming and debugging |
HSE OSC_IN / OSC_OUT |
|
External 8 MHz crystal |
Reserved input |
|
Factory firmware configures this as floating input |
External SPI Settings
Item |
Value |
|---|---|
Mode |
Slave |
SPI mode |
Mode 0 |
Bit order |
MSB First |
Data width |
8 bit |
Secondary Development Framework
The existing SANPO SPINE capabilities are retained. External sensors and other devices can be expanded through UART, I²C, and ADC.
Custom Development Framework
Use this framework for custom functionality. The project already configures the functional pins of both MCUs, so application logic can be developed directly.
Wiring Notes
Install suitable termination resistors at both ends of a CAN/CAN FD bus. Do not reverse CAN_H and CAN_L.
RS485 A/B naming may be reversed between vendors. If communication fails, check the transceiver markings and wiring.
Connect USB, the SPI host, and external devices to a common ground.
The two MCUs have independent USB and SWD interfaces. Do not mix them during firmware updates or debugging.